Anagha Dangle
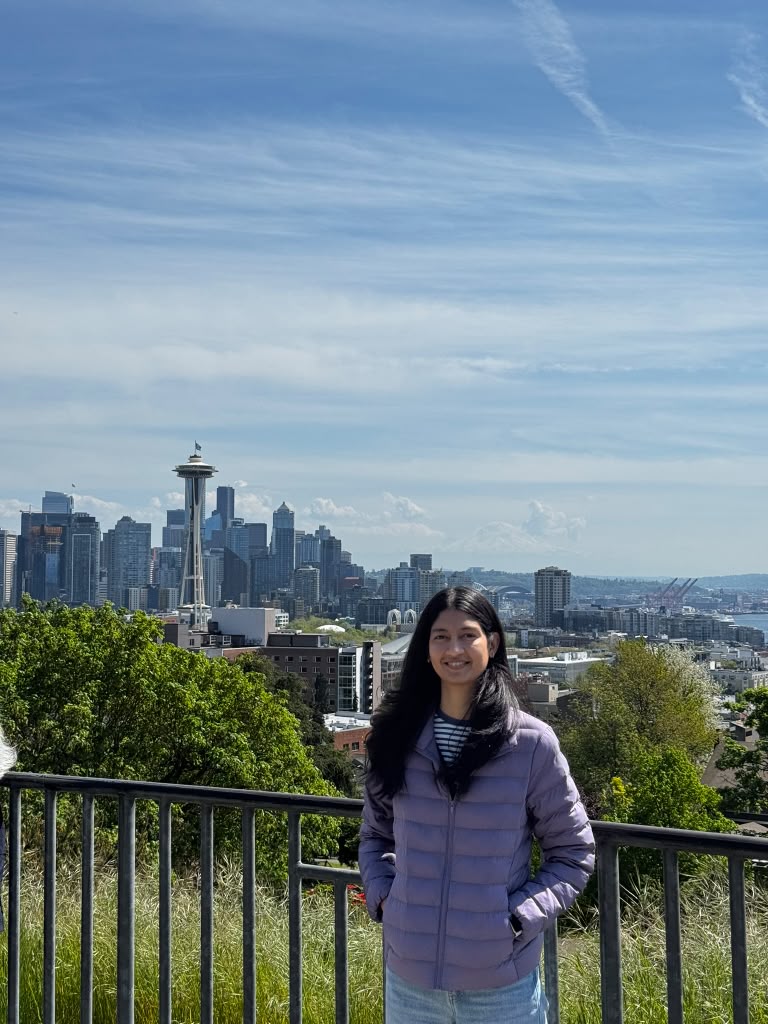
I'm a first-year Ph.D. student at Johns Hopkins University, where I work with Prof. Krishna Murthy Jatavallabhula at the SciPhy Lab. I'm broadly interested in dexterous manipulation, with my current focus on leveraging tactile sensing and other active sensing mechanisms for contact-rich manipulation.
Professional
Before Hopkins, I was a Robotics Engineer at Amazon Robotics, working at the Innovation Lab on some very cool projects, which is about as specific as I can be! I received my M.S. in Robotics Engineering from Worcester Polytechnic Institute in May 2024. At WPI, I worked on context-aware dexterous manipulation, advised by Prof. Berk Calli. My thesis was supported by the Amazon Robotics Greater Boston Tech Initiative grant. I’ve also interned at several other companies and startups, which are listed in my Experience section.
Personal
Kind of obvious, but I love working with robots. I participated in ABU Robocon during undergrad, and since then I’ve worked on almost every kind of robot you can imagine (or at least it feels that way). I also love reading a lot, mostly in my native language, taking photographs, and, more recently, writing again. I like trying random art projects and new food too, and I usually do really well, if I say so myself.
I'd love to connect if you're interested in collaborating, or just want to talk research. Feel free to reach out!
News
- Sep 2026Started writing a blog; the first post is How I Organize My Research Links and Resources.
- Aug 2026Began my Ph.D. at Johns Hopkins University.
- Nov 2024Presented our dexterous picking work at IEEE Humanoids 2024 in Nancy, France.
- May 2024Presented our dexterous picking research at NEMS 2024.
- Apr 2024Defended my master's thesis on context-aware robotic manipulation.
Experience
Selected Publication
Blog
I started writing to document what I’m learning, remember the random cool things I’ve worked on, and share the kind of starting points I once looked for.
The thoughts are all mine, and, for now, the grammar is corrected with AI. As I write more, I want to rely on AI as little as I can. Writing with AI is becoming increasingly common, and I think the little flaws that make human writing human are becoming strangely rare, so I want to keep mine.
How I Organize My Research Links and Resources
A working document on keeping track of papers and research links, starting with Brave bookmarks and a searchable Google Sheets index.
Read More →Projects
ROBOCON 2021
A high-agility swerve-drive robot with a flywheel-based projectile mechanism and pneumatic autoloader for throwing arrows into pots.
ROBOCON 2022
An omni-drive mobile manipulator with a dual slider-crank parallel gripper for autonomous object detection and precision stacking.
ROBOCON 2020
A synchronized ball-transfer system using a roller-flywheel mechanism for robust, high-speed handoffs between mobile robots.
ROBOCON 2019
Built from scratch, an autonomous quadruped robot powered by linear actuators and designed to traverse the course without wheels like a robotic horse.